Faster robot picking deployment
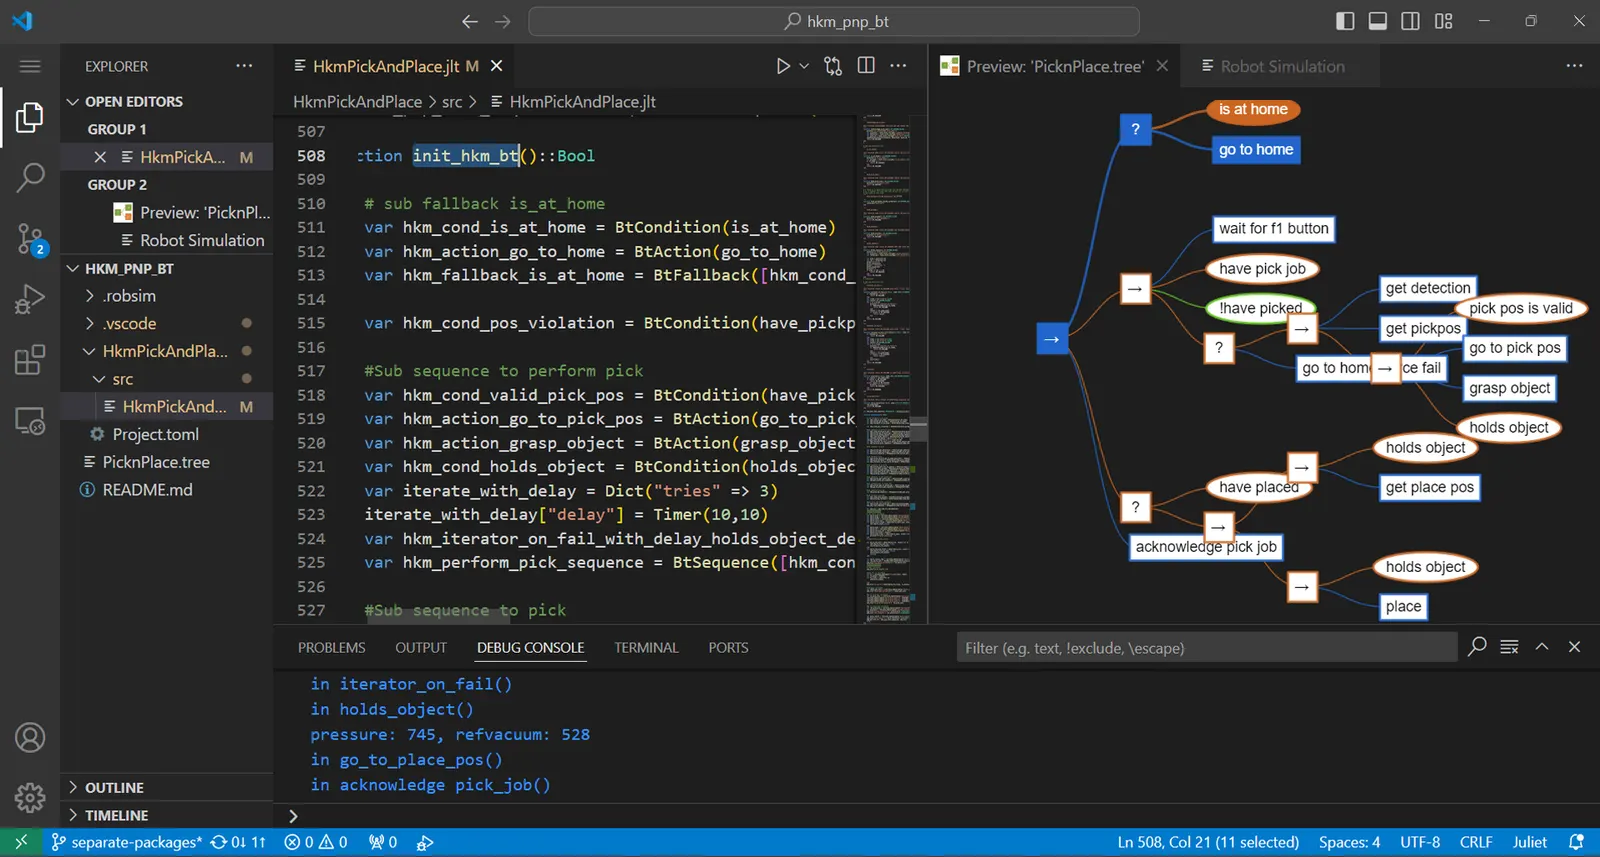
Johan Lindberg demonstrates how Juliet & Romeo coordinate robot motion, vision, tooling and surrounding systems in an HKM1800 picking application, as one automation workflow.
Watch the demonstration
Juliet is a generic robot programming language that is low-latency, real-time and multitasking, while staying safe with automatic memory management. Romeo is the real-time virtual machine that runs it. Together they give machine builders and integrators one platform for programming, execution and system evolution.
Cognibotics' own figures for Juliet & Romeo across the automation lifecycle.
less setup time at commissioning, and 50% lower support costs
higher throughput, up to, by automating more tasks
talent pool, as software developers can build automation
less change effort through modular updates
Juliet & Romeo brings together expressiveness, real-time performance, modern software development and ease of integration, principles that have not been combined in one solution before.
It is built for co-existence. Instead of replacing what is on the line, it works with community standards such as SRCI, IEC 61131 and ROS 2, so earlier investments stay protected while systems modernise step by step.
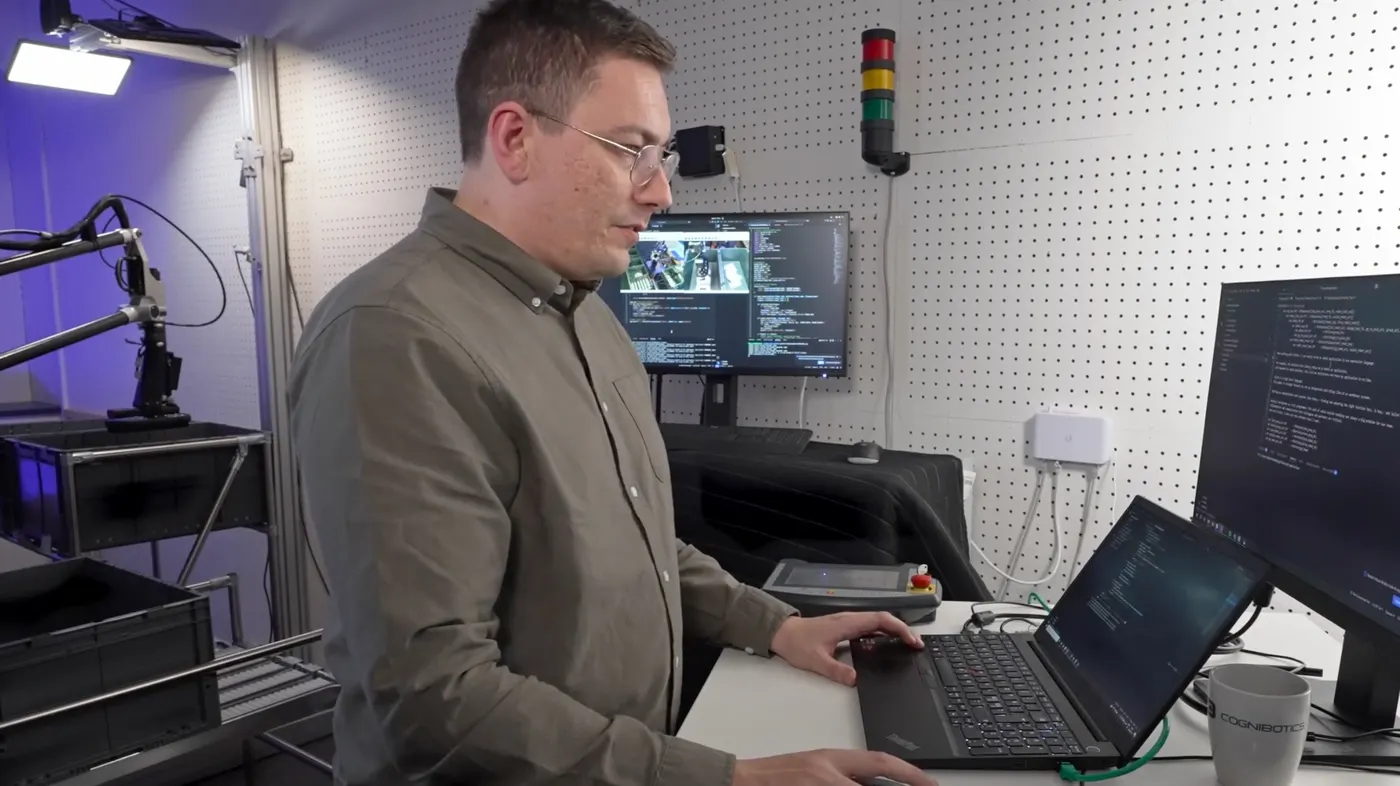
Johan Lindberg demonstrates how Juliet & Romeo coordinate robot motion, vision, tooling and surrounding systems in an HKM1800 picking application, as one automation workflow.
Watch the demonstration
Founder and CTO
Juliet & Romeo grew out of the robotics research at LTH, Lund University, where Cognibotics began. The team includes many PhDs in automatic control, mechatronics and software technology.
About the companyIntegrations for both are available today. Tell us about your machine and we will set up an evaluation.